
ロボット工学を探る
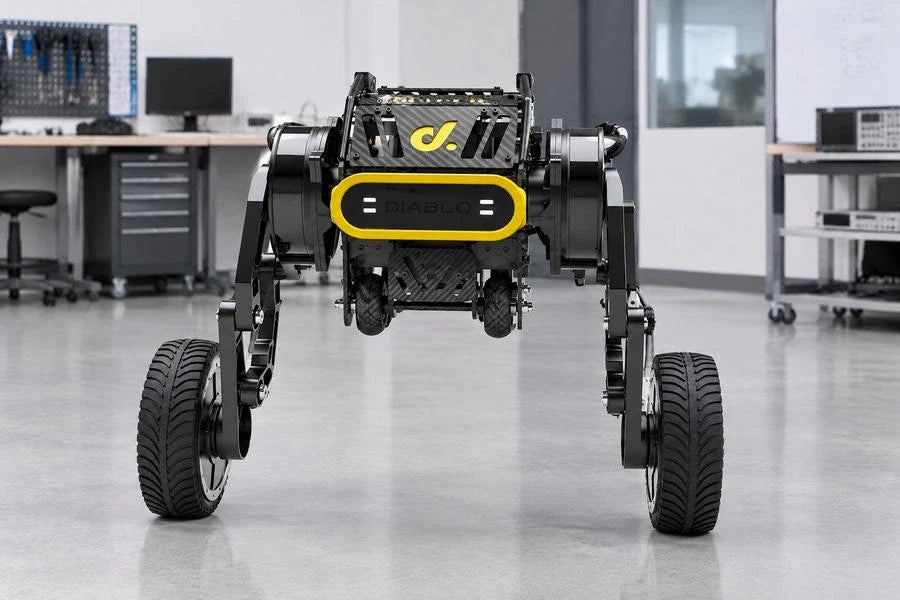
DIABLO
DIABLO Four-Bar Linkage Leg Robot: Mechanical Design for Terrain-Adaptive Motion
DIABLO uses a four-bar linkage leg to adjust body height and wheel geometry. Compare standing and creeping modes, payload limits, dimensions, and integration considerations.
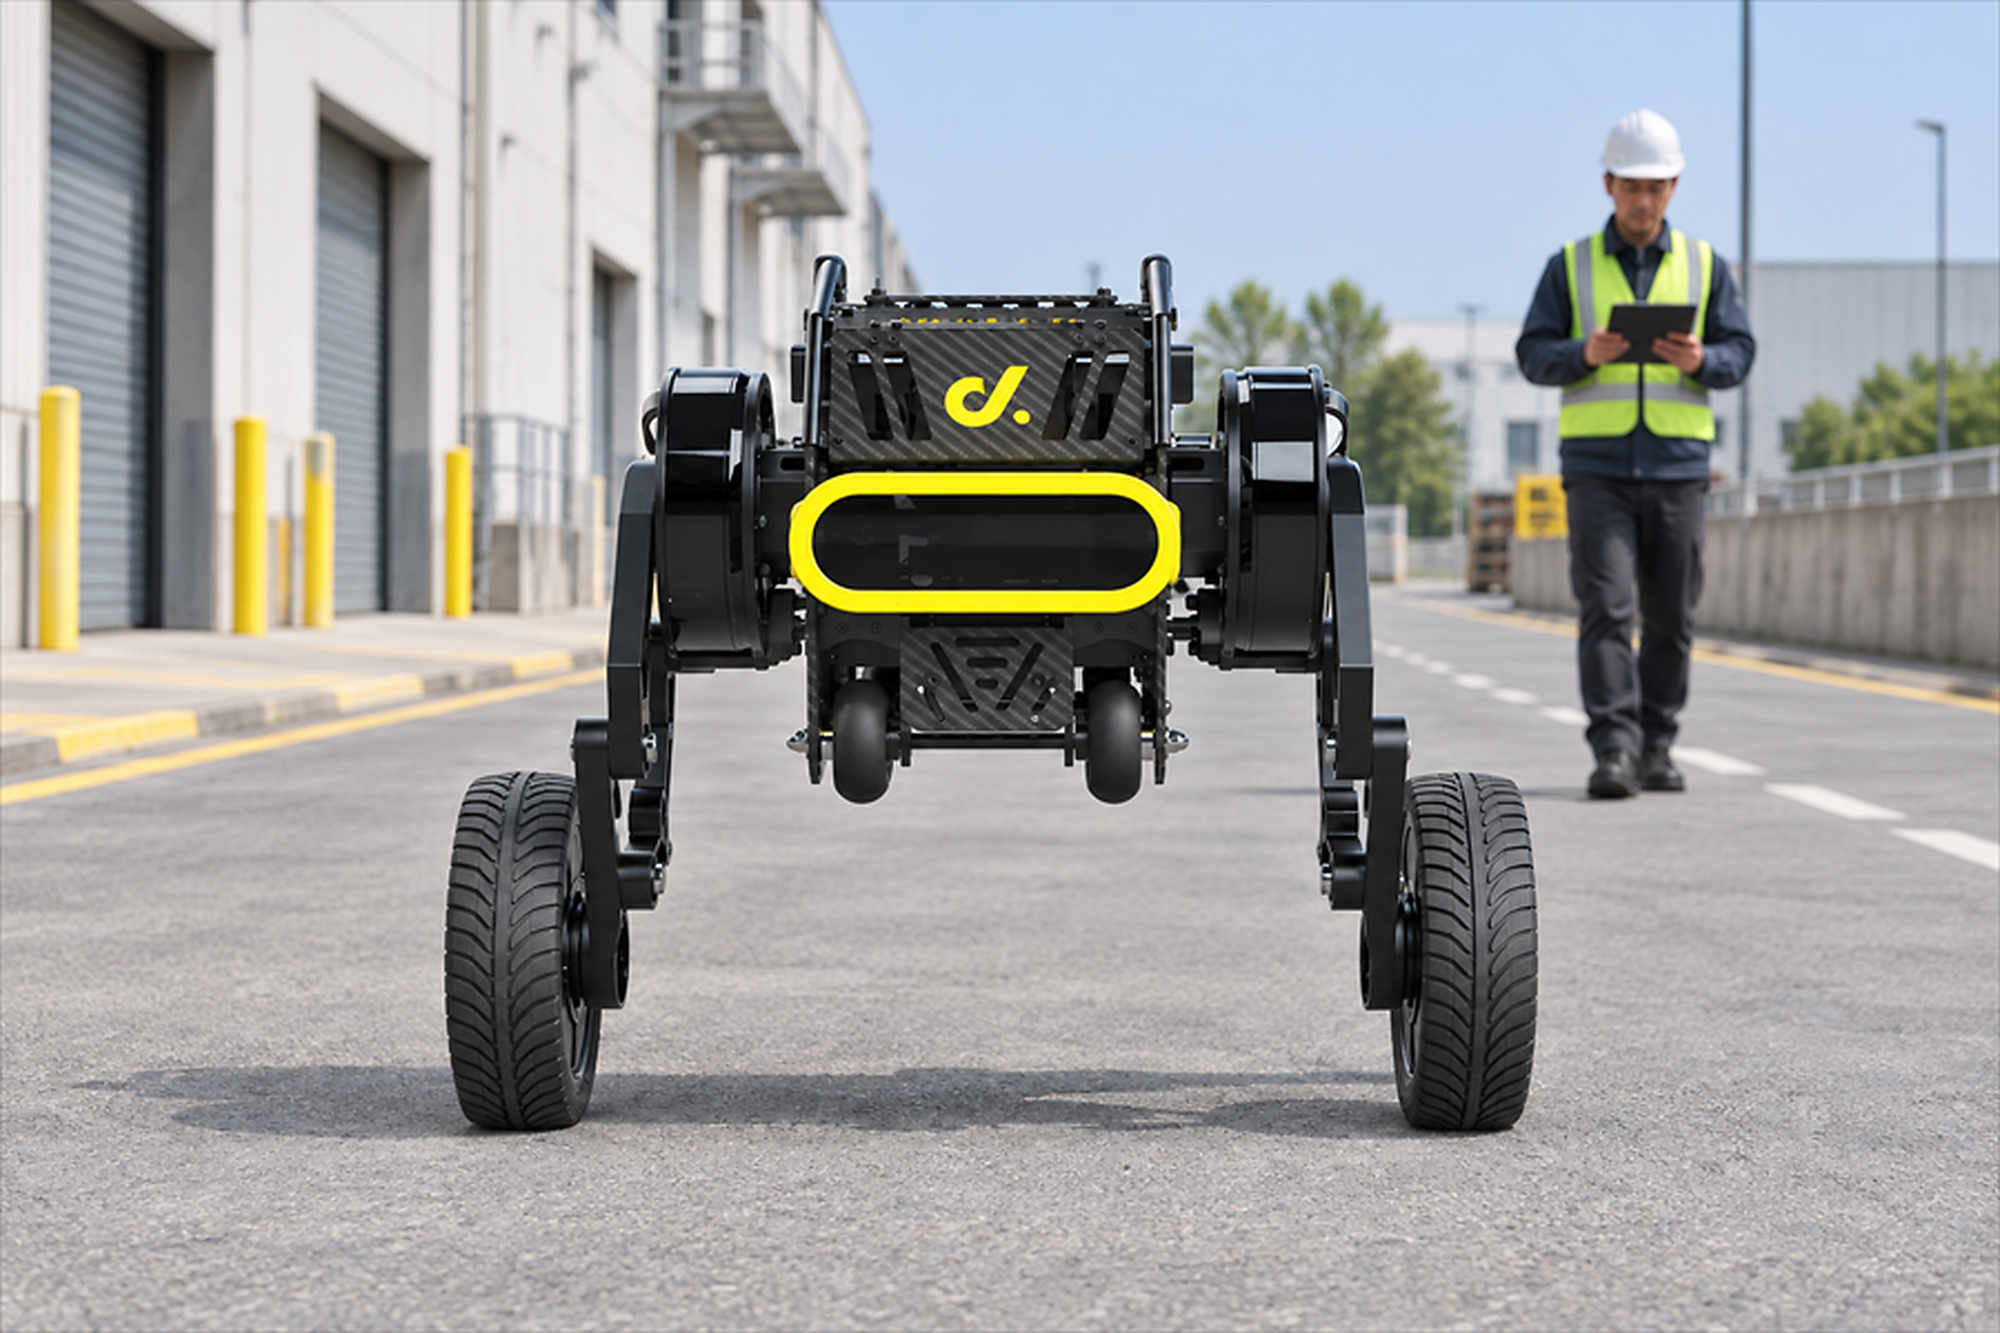
DIABLO
DIABLO Direct Drive Robot: The Origin of Its Unique Wheeled-Leg Appearance
Learn how direct-drive joints shaped DIABLO’s wheeled-leg design for efficient mobility, active balance, transport, and robotics research.
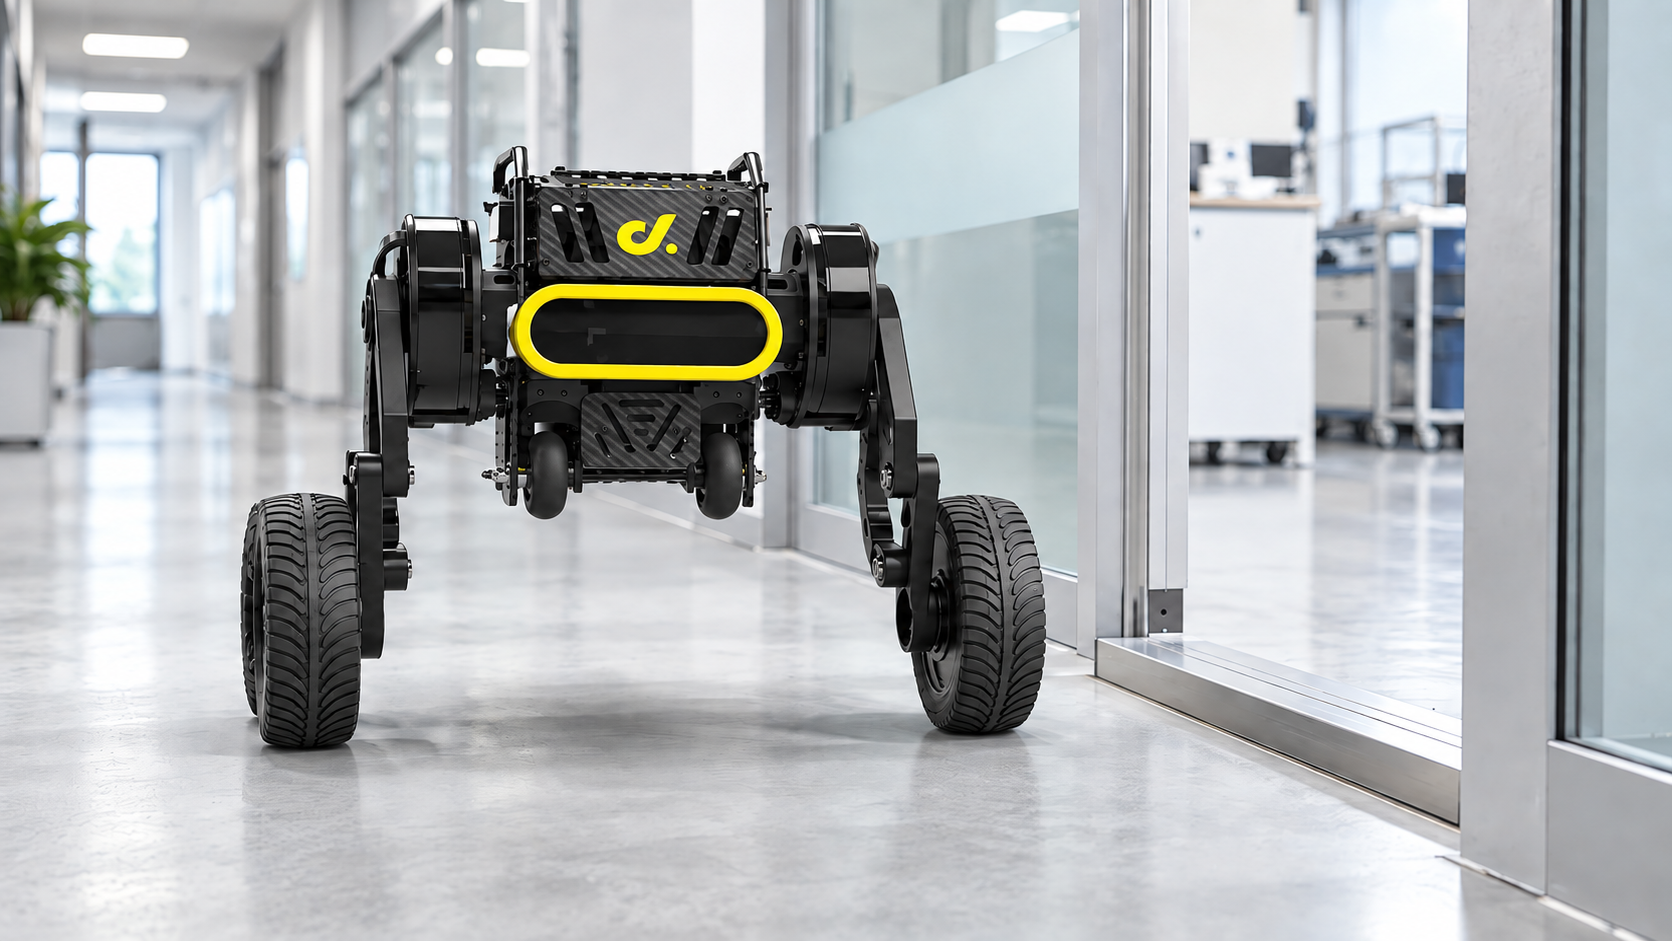
DIABLO
DIABLO Direct Drive Robot for Stable, Agile Real-World Mobility
Compare DIABLO’s standing, squatting, and creeping postures for payload, clearance, sensing, and route planning.