Robotics Blog
Diablo robot
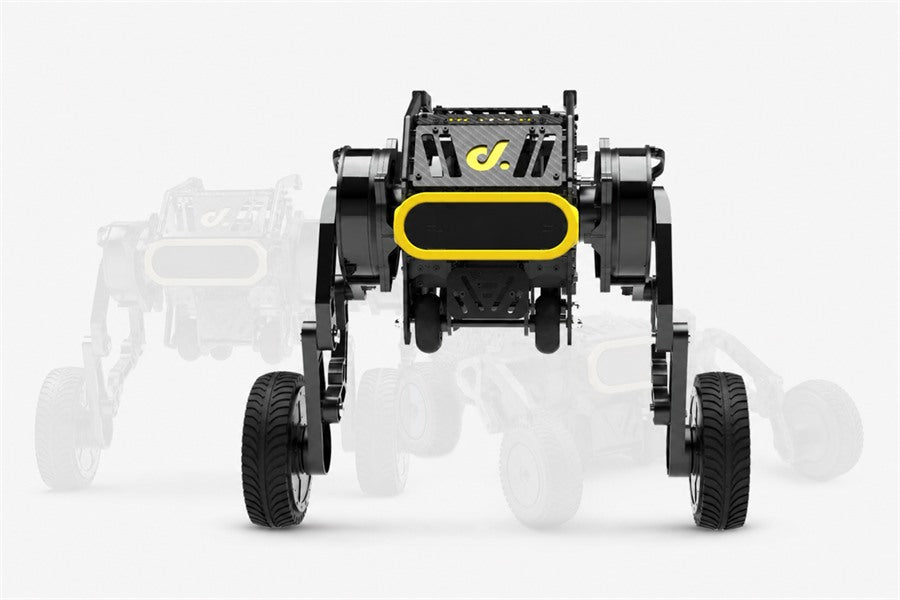
Inside Diablo: A Direct-Drive Self-Balancing Wheeled-Leg Robot Platform
Explore DIABLO’s direct-drive, self-balancing design, payload, speed, runtime, motor specifications, and open SDK. Contact Direct Drive Tech to discuss pricing, accessories, and integration require...
Diablo robot
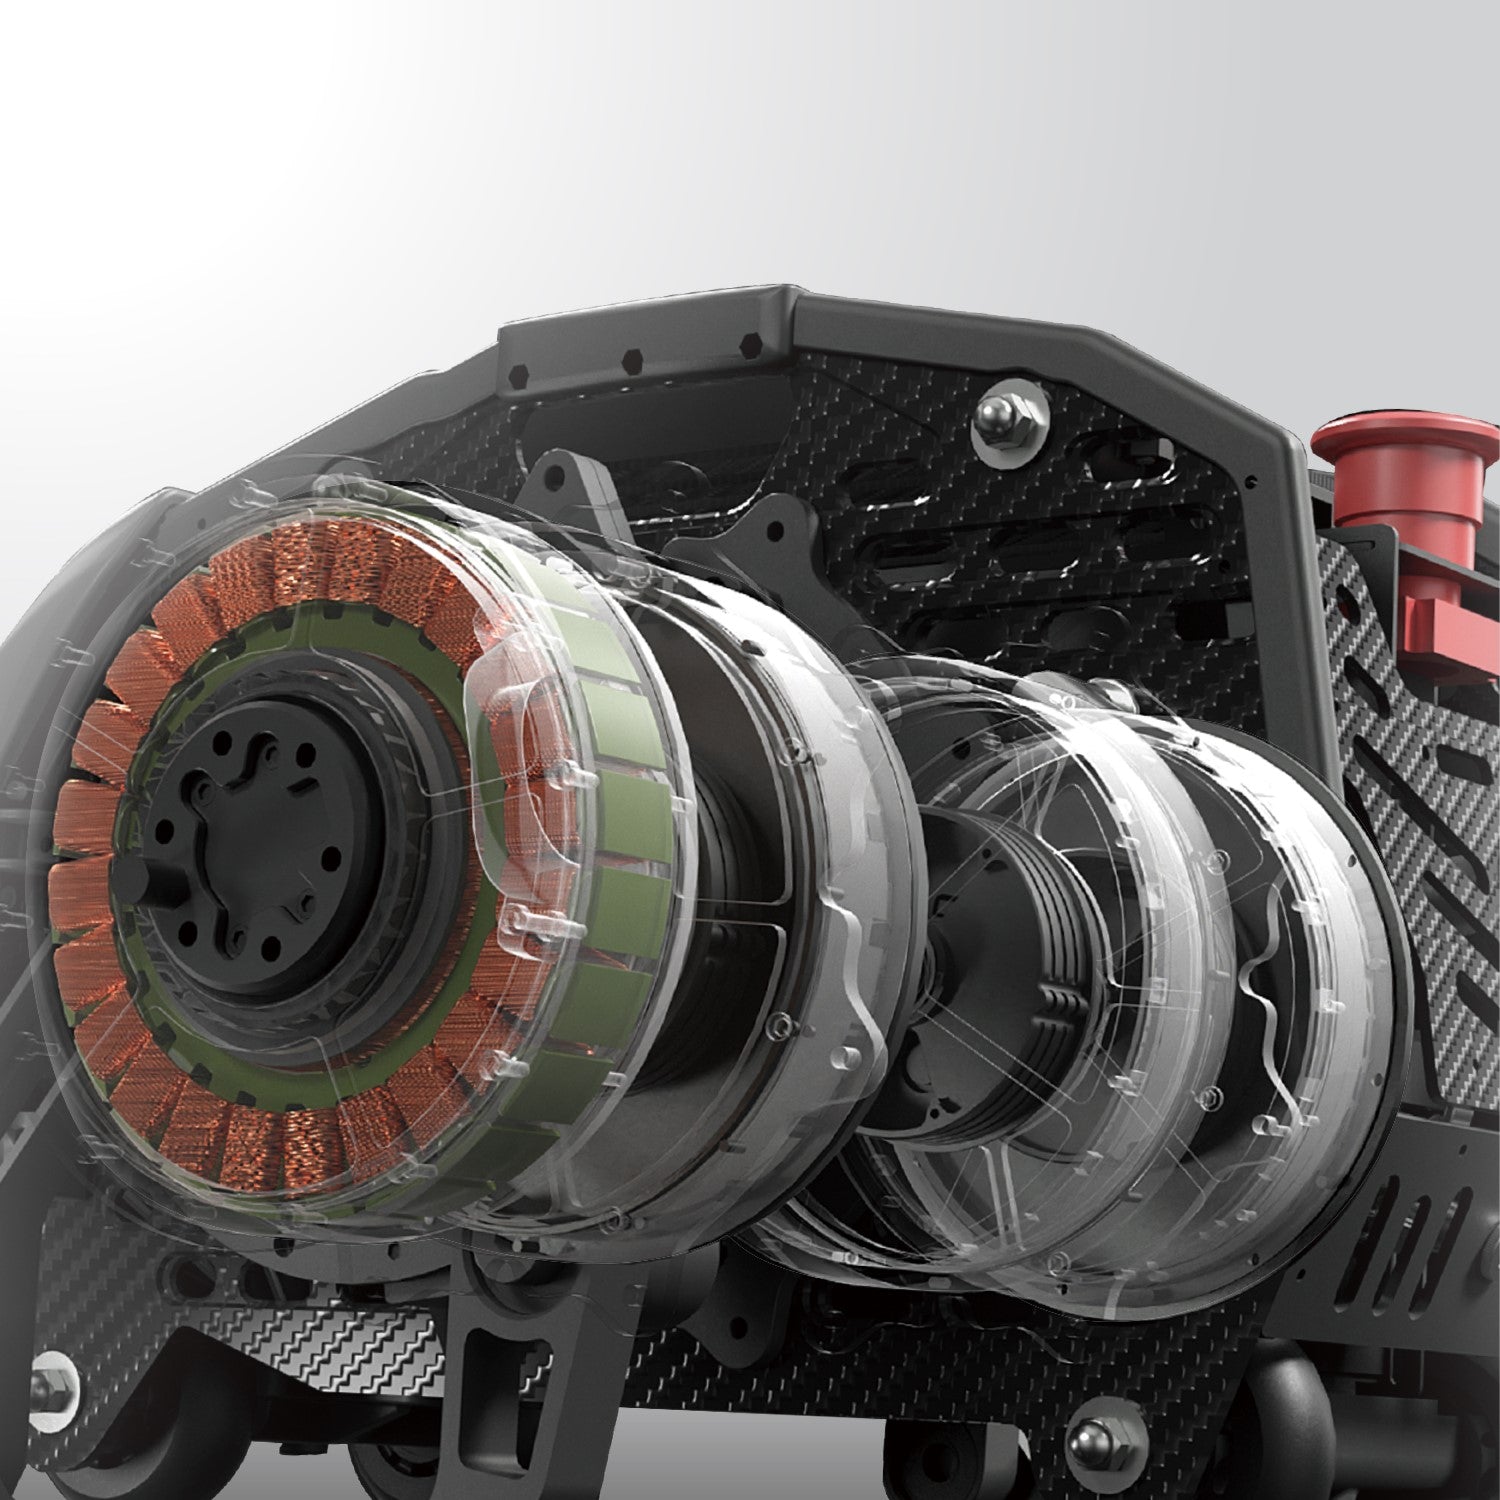
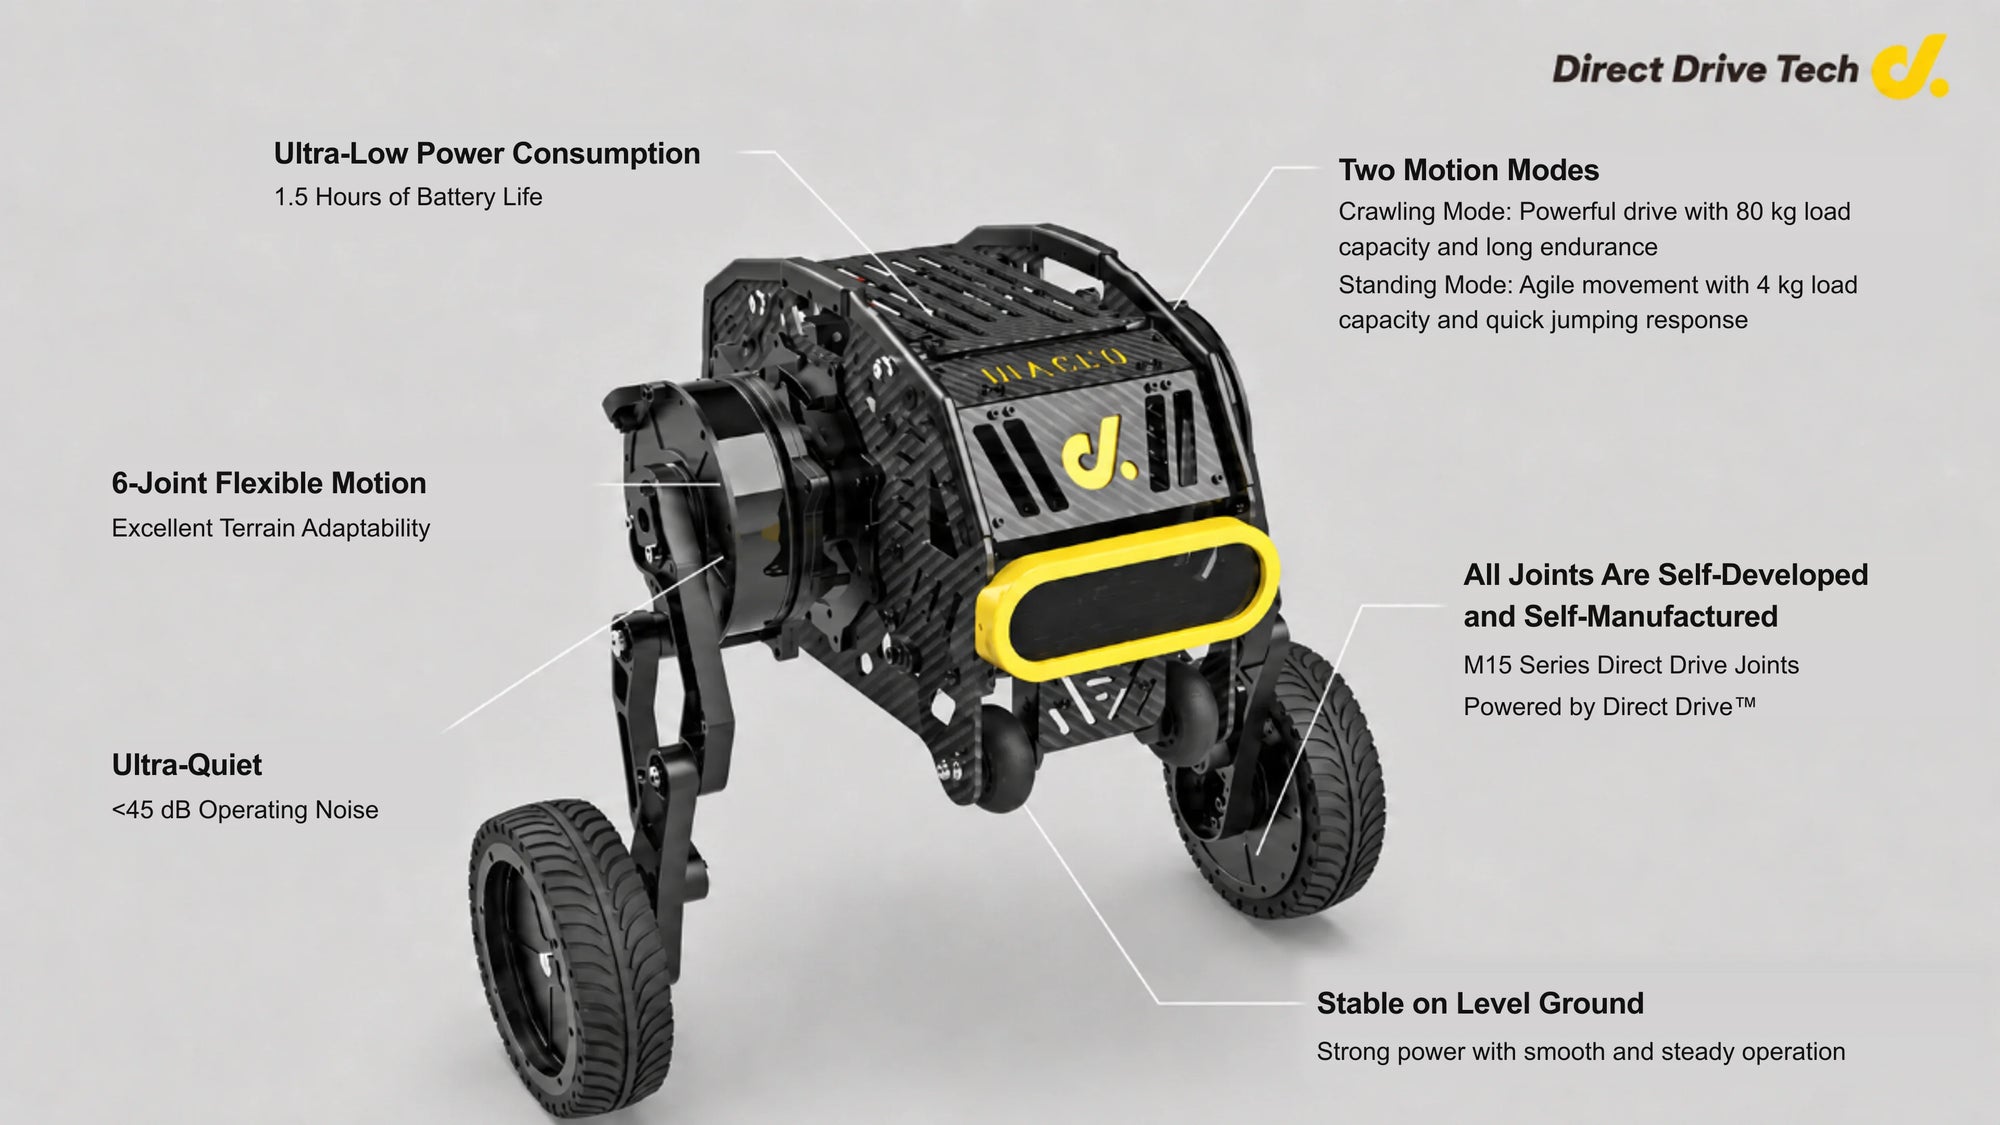
Diablo Robot: A Direct-Drive Wheeled-Leg Robot Development Platform Powered by RaspberryPi4ModelB
Explore Diablo, a direct-drive wheeled-leg robot platform powered by RaspberryPi4ModelB for edge AI, delivery, inspection, and robotics research.
robot actuator
Wheeled-Legged Robots Move from Labs to Industrial and Home Applications
Wheeled-legged robots support inspection, patrol, delivery, and emerging home applications. Compare Diablo, TITA, and D1 specs, and contact us for pricing.
Towards Efficient Trajectory Generation for Ground Robots beyond 2D Environment
With the development of robotics, ground robots are no longer limited to planar motion. Passive height variation due to complex terrain and active height control provided by special structures on r...
FAEL: Fast Autonomous Exploration for Large-scale Environments With a Mobile Robot
Abstract:
Autonomous exploration in large-scale and complex environments is a challenging task. As the size of the environment increases, the significant overhead of exploration algorithms could ov...
Edge-Assisted V2X Motion Planning and Power Control Under Channel Uncertainty
Edge-assisted vehicle-to-everything (V2X) motion planning is an emerging paradigm to achieve safe and efficient autonomous driving, since it leverages the global position information shared among m...