
Robotics Blog
D1 for Reinforcement Learning Robotics: Training Wheel-Legged Quadruped Locomotion in MJLab
See how D1 supports reinforcement learning robotics with MJLab flat and rough terrain tasks, NP3O training, checkpoint evaluation, and ROS 2 integration.
D1 BOX1 Material Handling Robot: Planning Autonomous Cargo Transport
Plan short-distance box transport with D1 × BOX1 for indoor routes and industrial parks. Check cargo fit, working loads and handover before a site pilot.
TITA Follow-Me Robot: UWB Person Tracking for Hands-Free Mobile Tasks
TITA's optional UWB follow-me setup uses wristband tracking for tool carrying, mobile sensing, and research. Learn what hardware and software it requires.
DIABLO
DIABLO Direct Drive Robot: The Origin of Its Unique Wheeled-Leg Appearance
Learn how direct-drive joints shaped DIABLO’s wheeled-leg design for efficient mobility, active balance, transport, and robotics research.
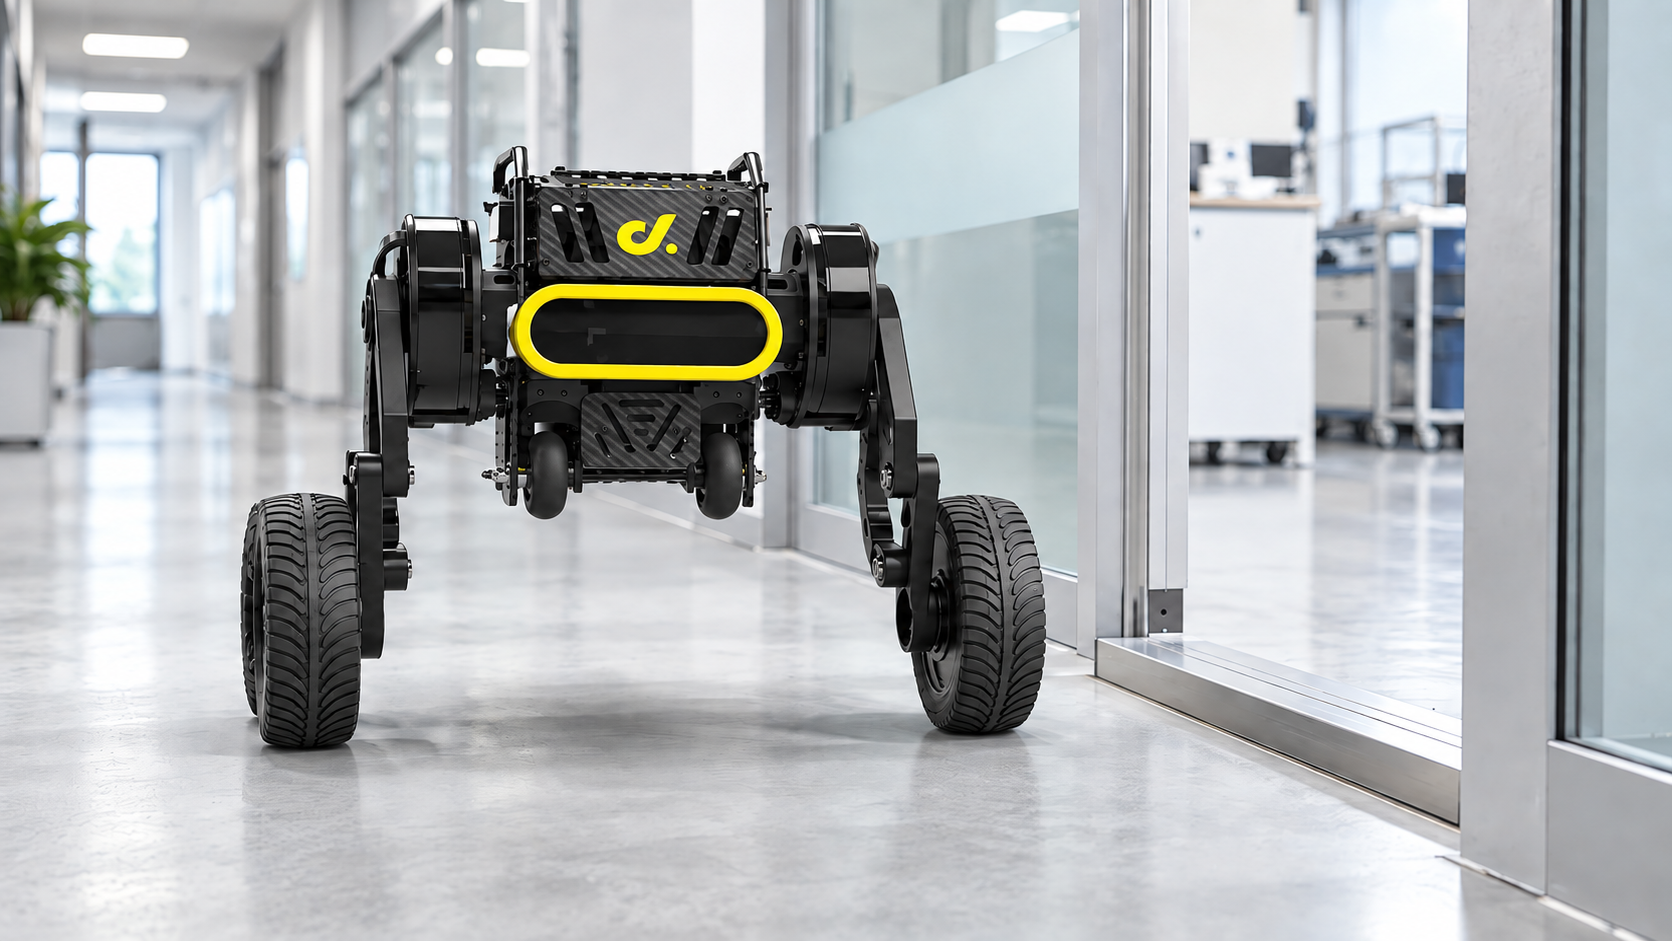
DIABLO
DIABLO Direct Drive Robot for Stable, Agile Real-World Mobility
Compare DIABLO’s standing, squatting, and creeping postures for payload, clearance, sensing, and route planning.
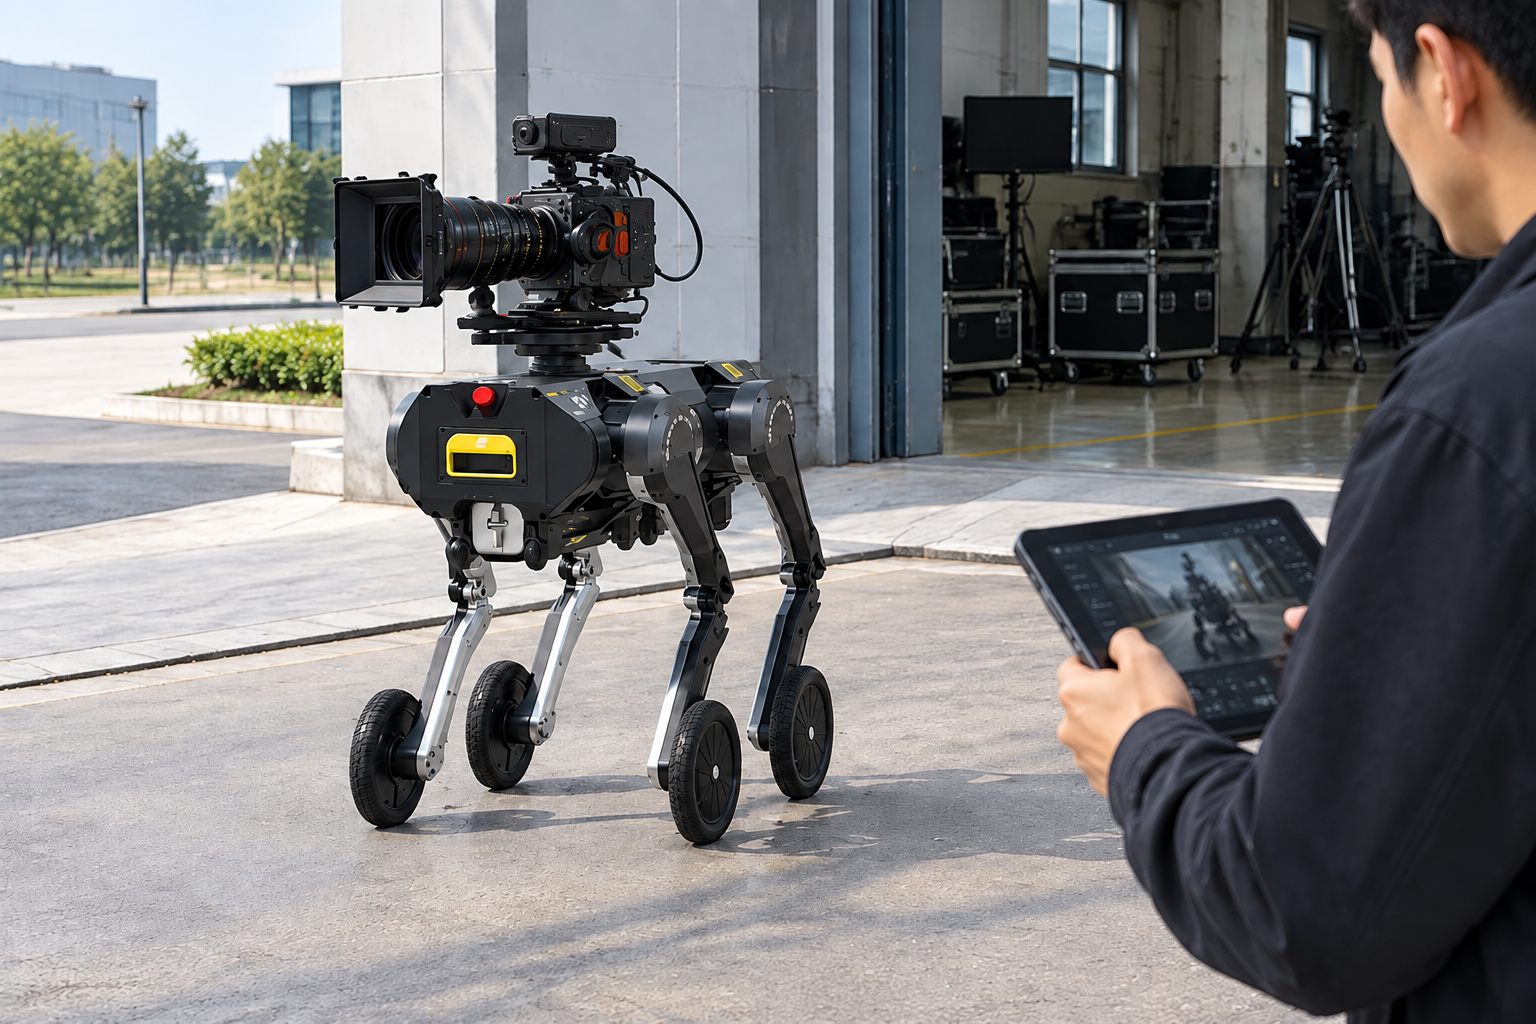
Camera Robot
D1 Robot Brings Flexible On-Site Mobility to Mobile Filming Applications
Our D1 robot supports complete camera setups, adaptable camera routes, outdoor mobility tests, and sensing integration within one modular platform.
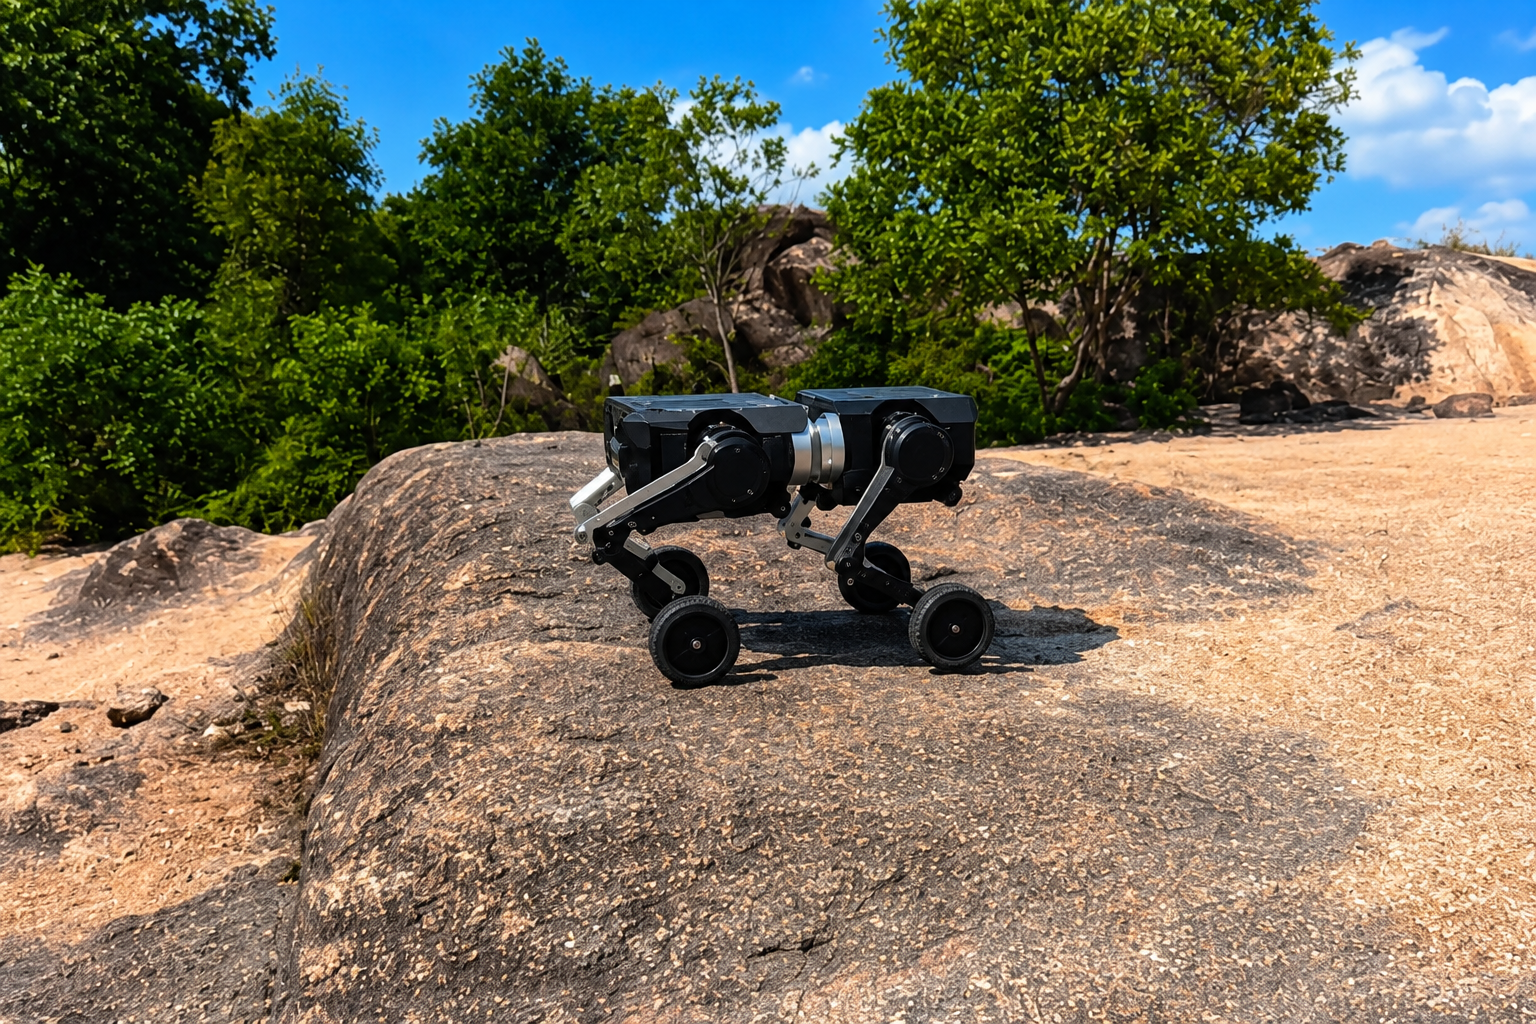
D-infinite
D-infinite Multi-Form Robot Expands Real-World Applications Through Flexible Form Switching
A robot that performs well in a lab can still struggle when the ground, payload, or mission changes. D1, also called D-infinite, is designed to switch its stance and locomotion form as the job chan...
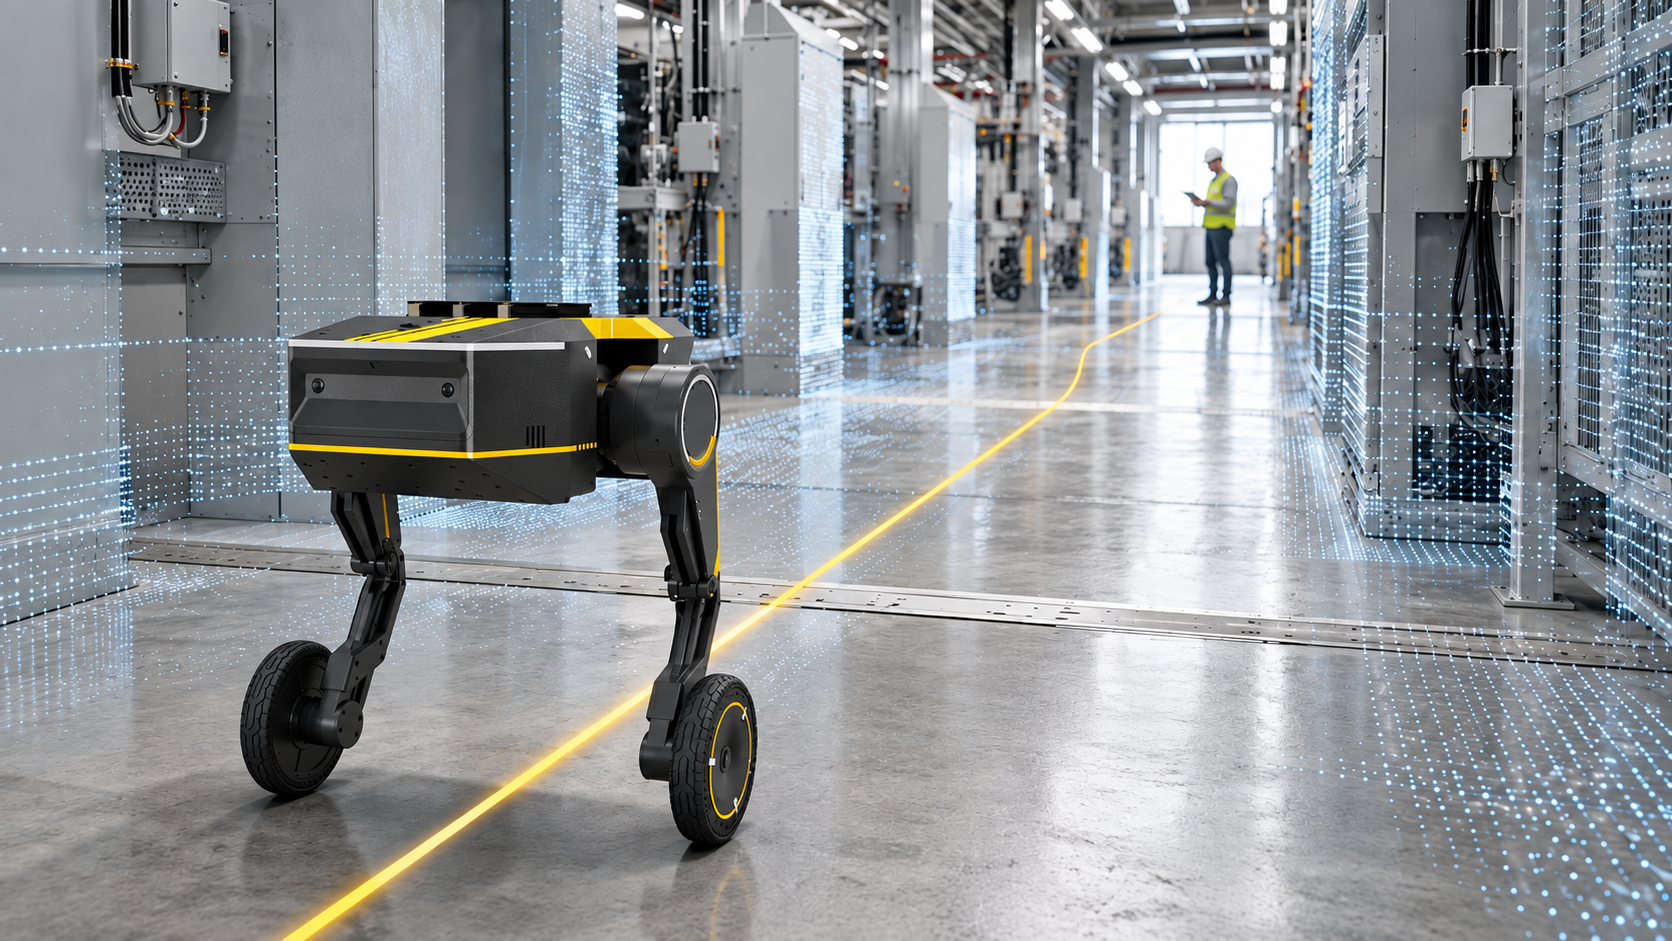
Autonomous Robots
How to Evaluate a SLAM Mapping Robot for Inspection and Site Surveys
A practical SLAM mapping robot should be evaluated as a complete field system, not by its mapping demonstration alone. At Direct Drive Tech, we recommend checking five areas: whether the robot can ...
3D perception
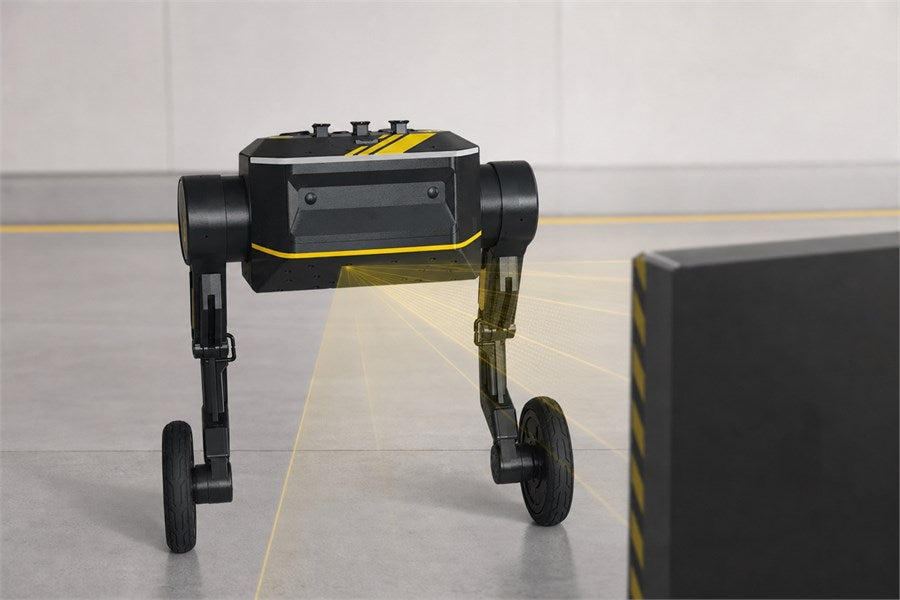
TITA Robot Enhances 3D Perception and Autonomous Obstacle Avoidance with Multimodal Sensing
TITA uses multimodal sensing to improve autonomous robot navigation, 3D perception and obstacle avoidance in real-world inspection, mapping and research environments.