
ロボット工学を探る
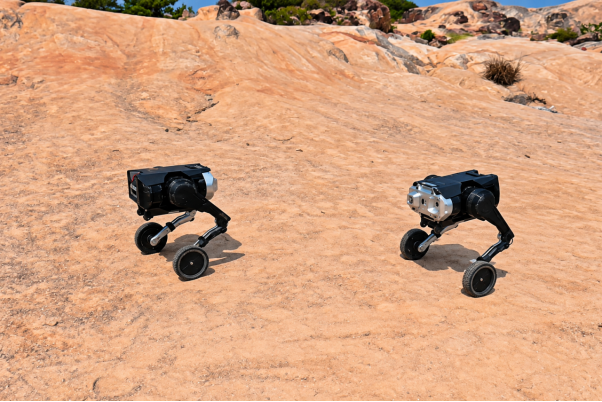
Multi-Robot Coordination for Modular Robots
Multi-Robot Coordination for Modular Robots in Complex Environments
At Direct Drive Tech, we view multi-robot coordination as the ability of several robots to act as one team rather than simply ...
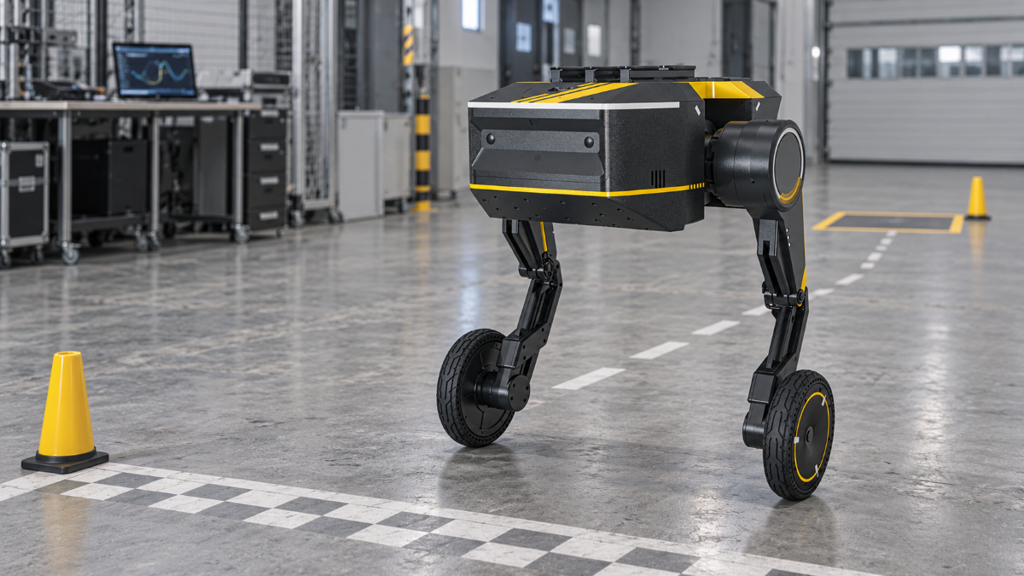
How to Test TITA at 3 m/s vs. Up to 5 m/s: A High-Speed Robot Decision Guide
Can TITA run at 5 m/s, and is the faster mode worth using? Its published maximum speed is 3 m/s, with up to 5 m/s available through an API unlock when the project environment and safety controls a...
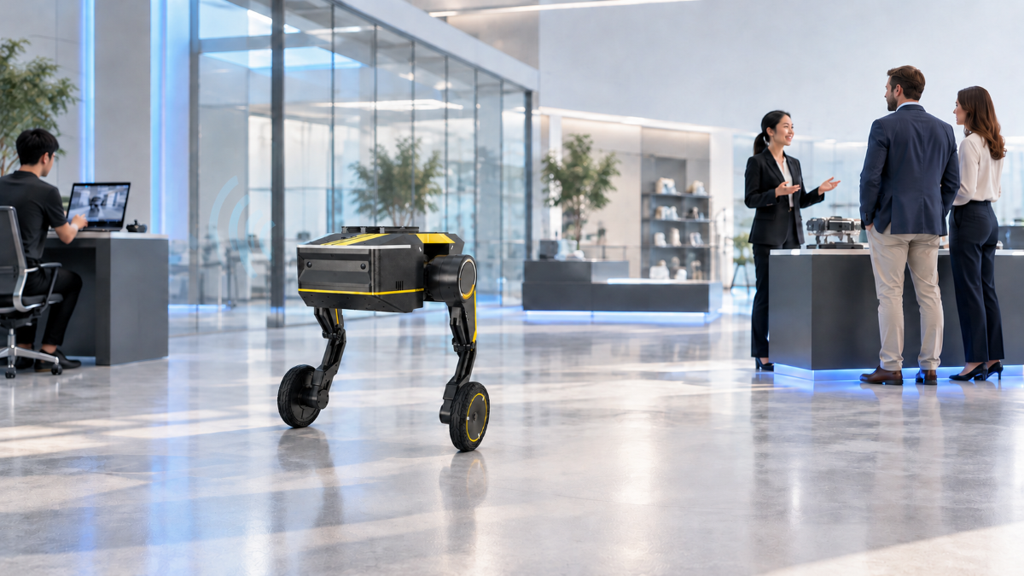
TITA Reception Robot: Remote Video, Speaker Audio, and Mobile
What Role Can a Mobile Robot Play in Visitor Reception?
If you are weighing a reception robot for a showroom or lab, the real question is what it will do during a visit and who stays in charge of ...
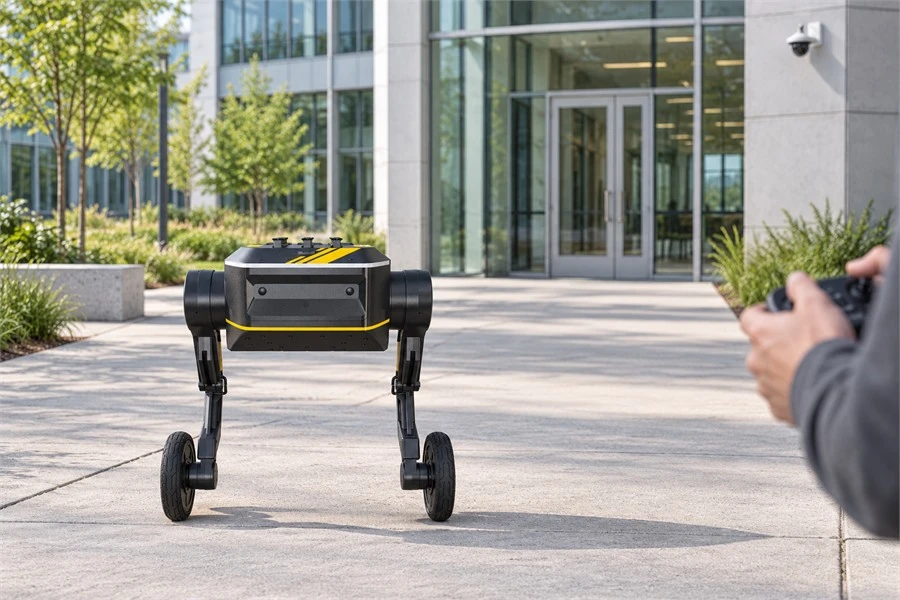
TITA Security Robot Platform for Remote Monitoring at Campuses and Industrial Sites
At a campus or industrial site, a security team may receive an alert without knowing whether it requires immediate intervention. A fixed camera can provide context from one angle, but it cannot fo...
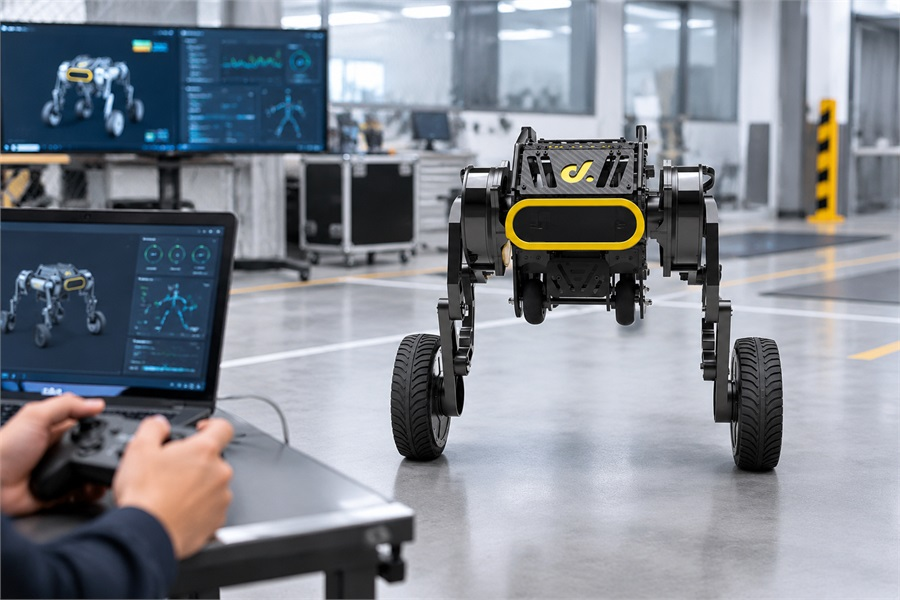
DIABLO Robot Teleoperation: Human-in-the-Loop Control for Remote Interaction
Learn how to remotely control DIABLO through ROS 2, use keyboard or RViz2 teleoperation, manage standing and creeping modes, and monitor robot feedback.
robotics
TITA Programmable Robot: API Access for Custom Robotics Applications
Explore TITA’s ROS 2 support, full-link API access, open Linux kernel source, 100 TOPS computing, and motor interfaces for custom robotics application development.
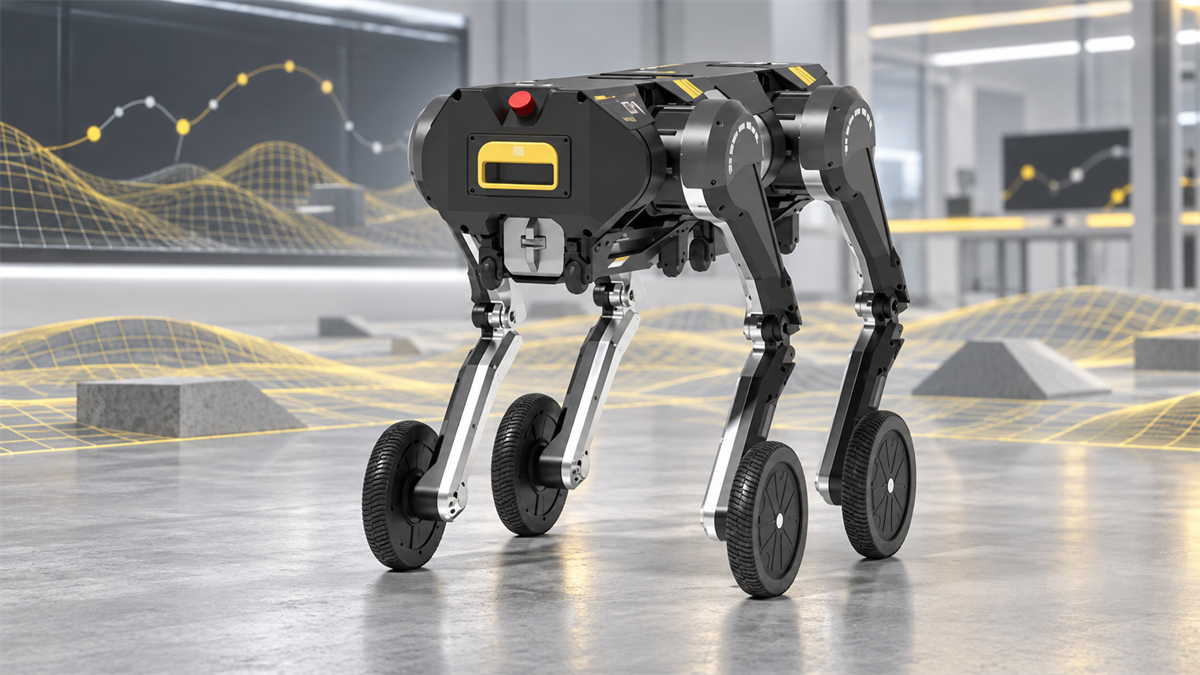
D1 for Reinforcement Learning Robotics: Training Wheel-Legged Quadruped Locomotion in MJLab
See how D1 supports reinforcement learning robotics with MJLab flat and rough terrain tasks, NP3O training, checkpoint evaluation, and ROS 2 integration.
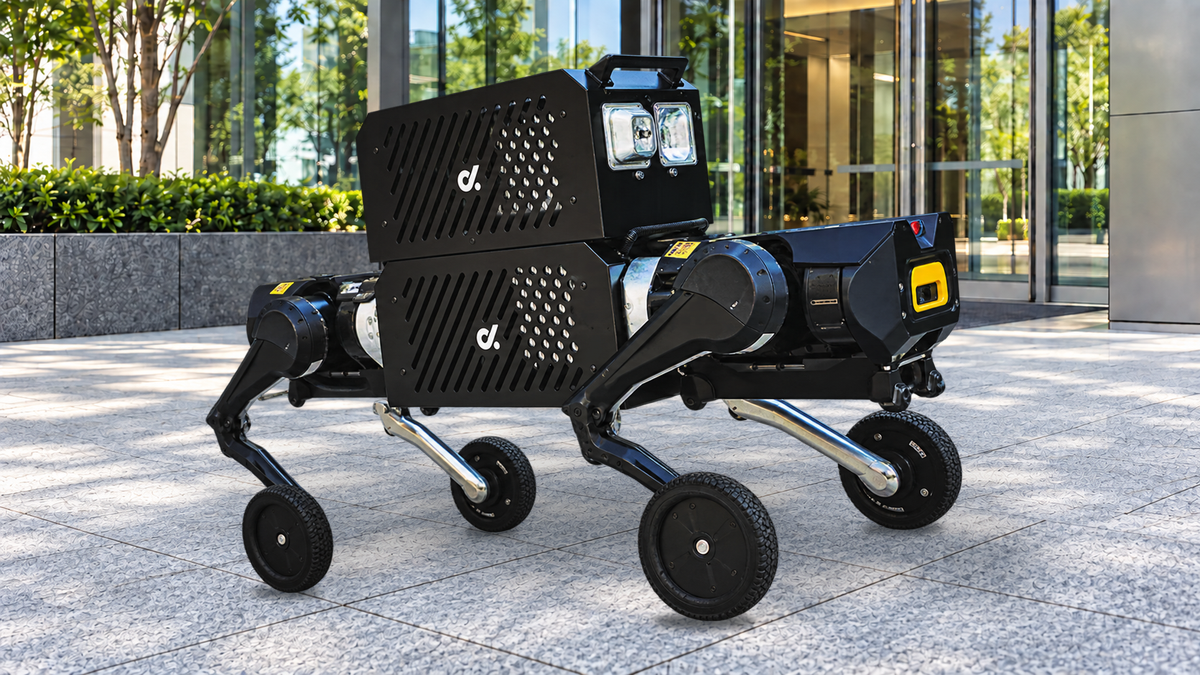
D1 BOX1 Material Handling Robot: Planning Autonomous Cargo Transport
Plan short-distance box transport with D1 × BOX1 for indoor routes and industrial parks. Check cargo fit, working loads and handover before a site pilot.
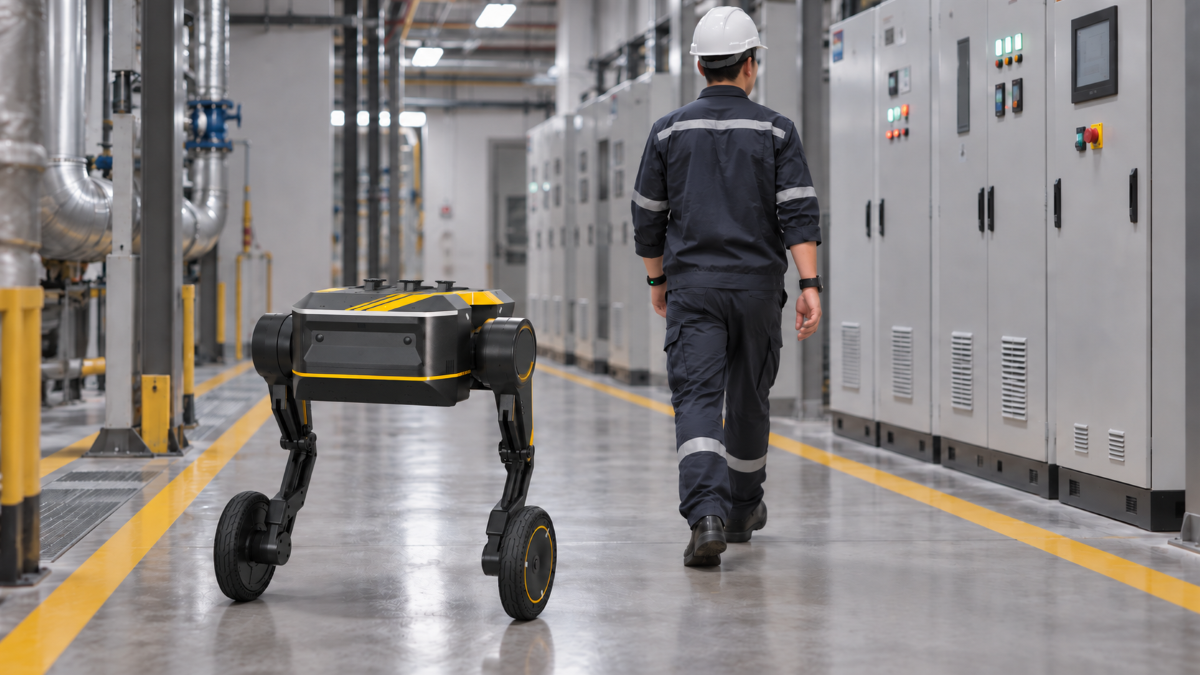
TITA Follow-Me Robot: UWB Person Tracking for Hands-Free Mobile Tasks
TITA's optional UWB follow-me setup uses wristband tracking for tool carrying, mobile sensing, and research. Learn what hardware and software it requires.